Selected work in robotics, world models, and generative-image detection.
4 projects
Bimanual manipulation
SWIVL
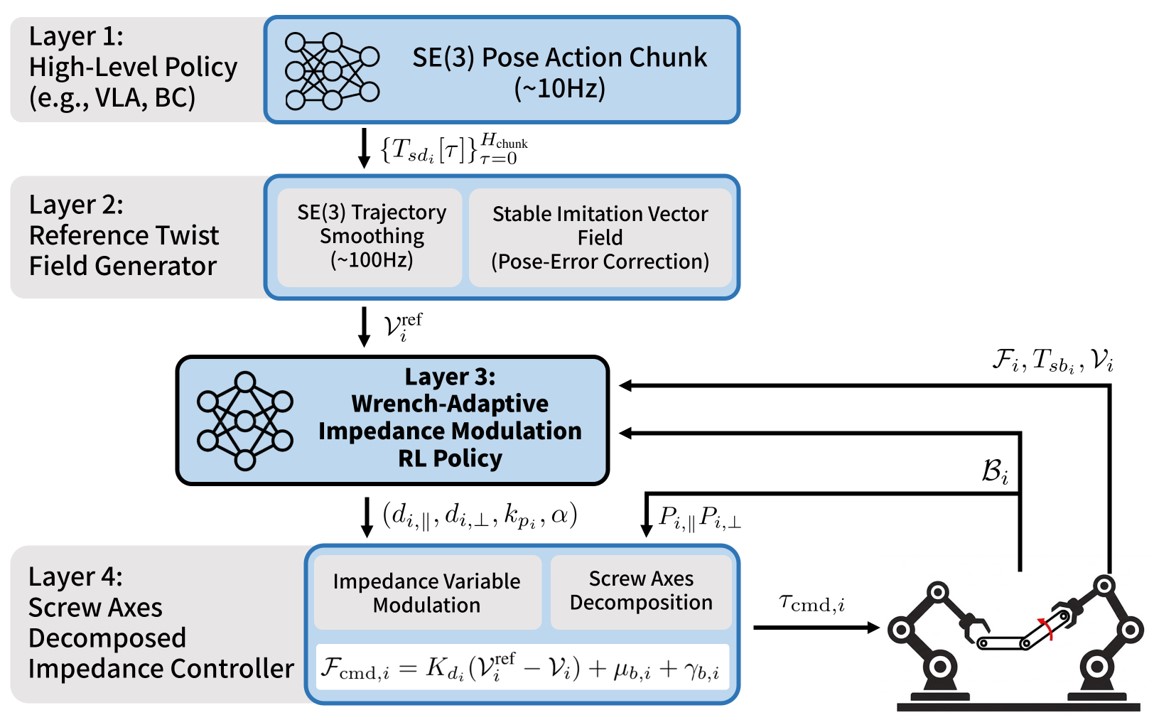
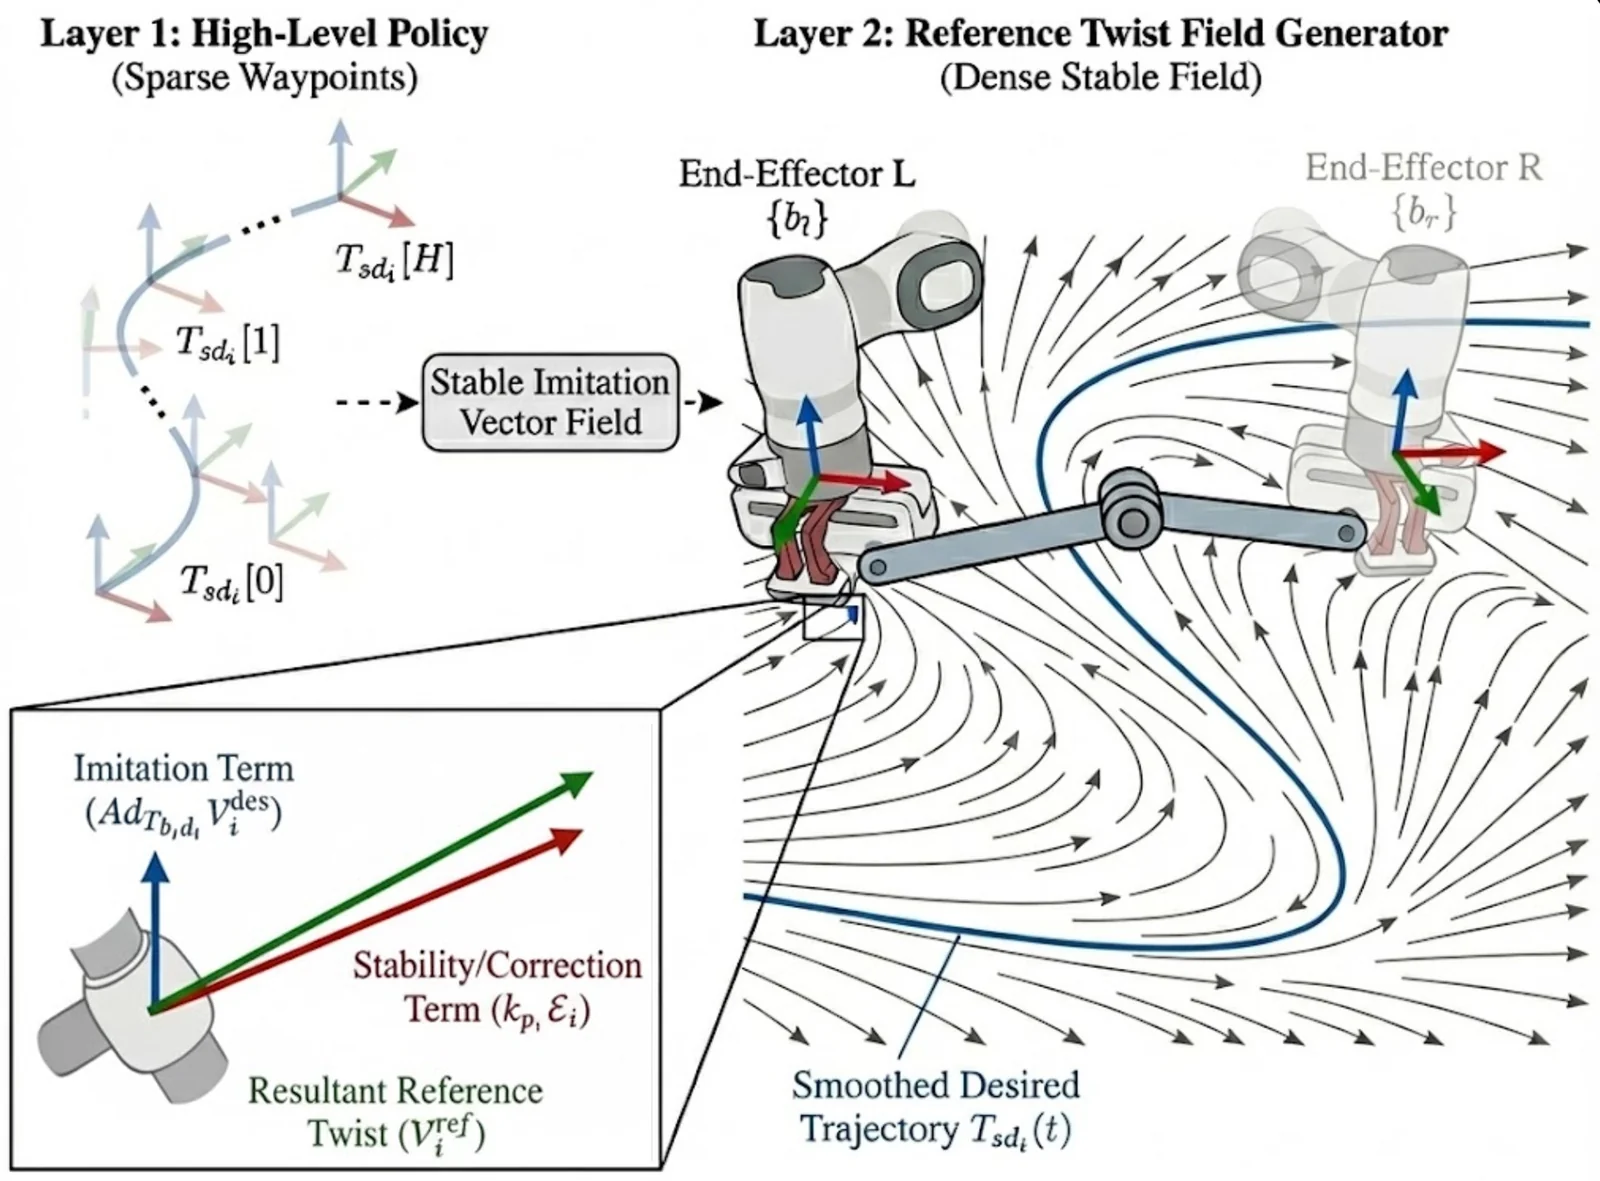
Connects learned motion plans to screw-decomposed impedance control for bimanual articulated-object manipulation. An RL policy uses object screw axes and wrench feedback to adapt compliance and reduce opposing forces between the arms.
World models and planning
LIVerse
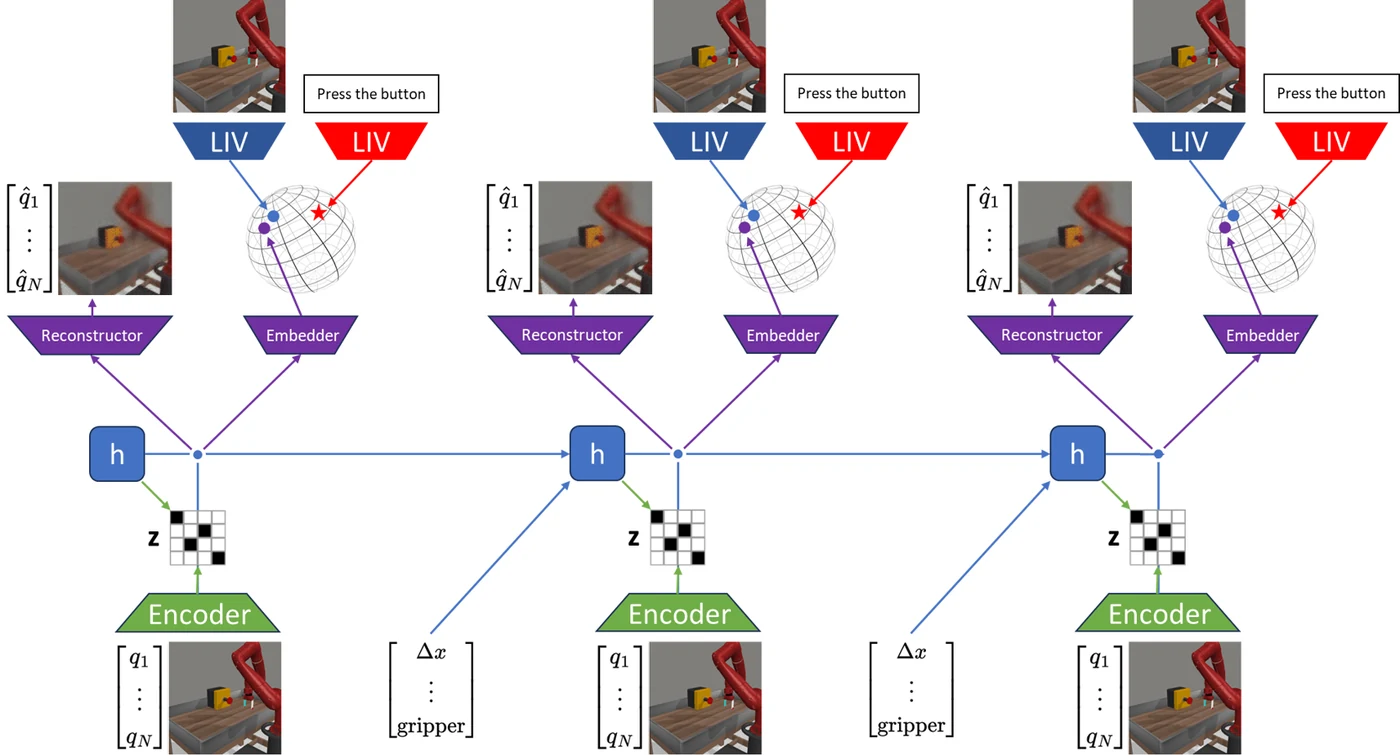
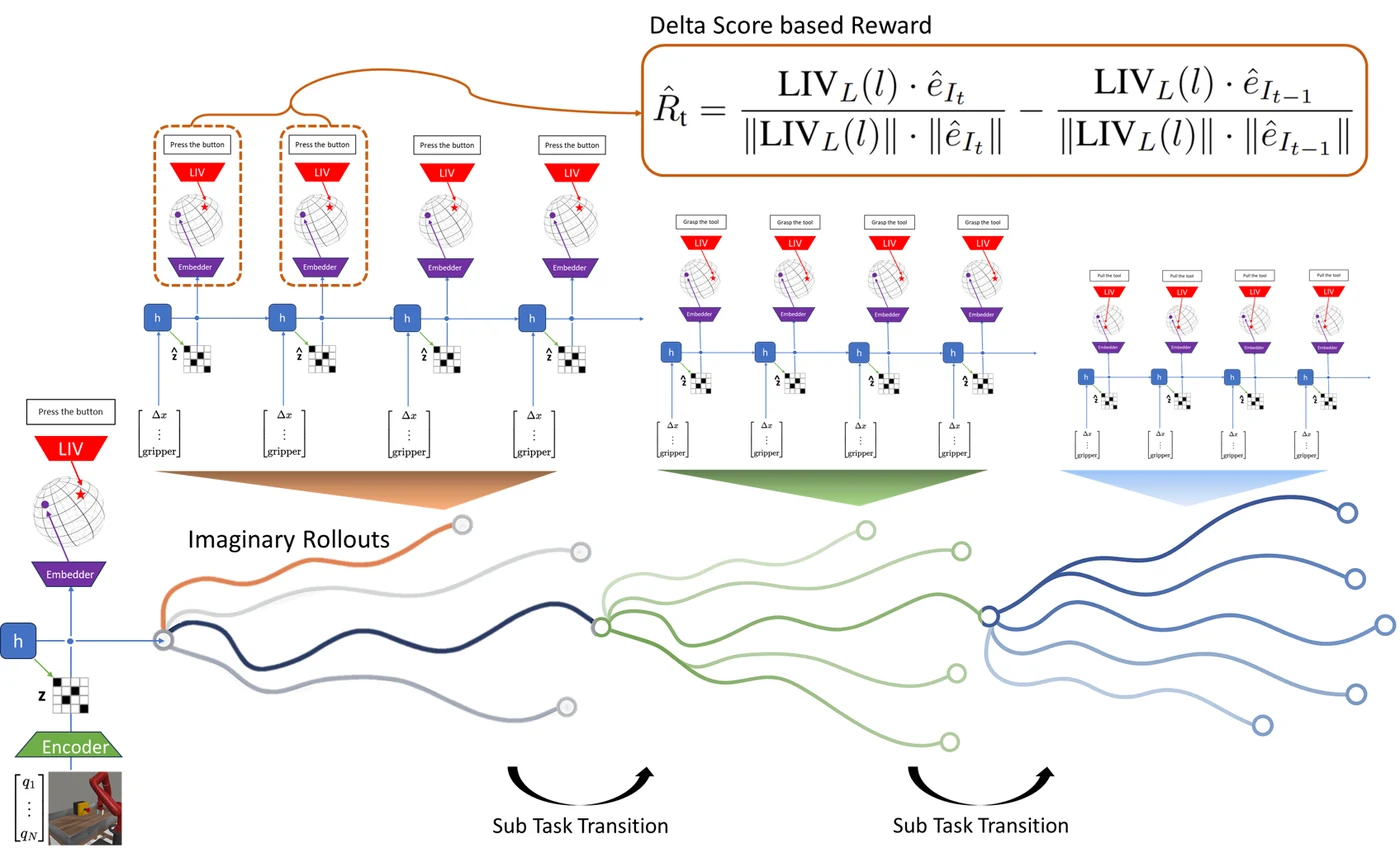
Predicts dynamics and vision-language embeddings in a recurrent world model for MPC with text or image goals. Delta-score rewards support sequential subtask planning without training a separate policy for each goal.
Computer vision · Aegis AI
K-Startup Challenge: Detection of Generative Images
Led development of Aegis AI's generative-image detection system for the K-Startup Challenge.
Technical Leader · Competition prize: US$11,000
Sim-to-real reinforcement learning
Auto Balancing Case
A self-balancing suitcase that shifts its center of mass under PPO control, trained in Isaac Lab and deployed on hardware. My contribution covered the simulation environment, policy training, and sim-to-real bridge.