I am broadly interested in control and planning of dynamic systems, particularly in robotics. My research objective is to enable robots to perform complex behaviors and exhibit physical intelligence through learning. These interests span both manipulation and locomotion in real-world robotics.

I am an M.S. student in Mechanical Engineering at KAIST, advised by Prof. Jemin Hwangbo in the RAI Lab. Previously, I was an undergraduate research intern in the Robotics Lab at Seoul National University, working with Prof. Frank C. Park.

Kyungseo Park

Education

KAIST

M.S. Student in Mechanical Engineering

RAI Lab · Advisor: Prof. Jemin Hwangbo

Fall 2026 - Present

Seoul National University

B.S. in Mechanical Engineering; B.S. in Electrical and Computer Engineering (Double Major)

Summa Cum Laude · Ranked 3rd in the department · GPA: 4.10/4.30

Mar 2020 - Aug 2026

Publications

Research & Engineering Experience

01Jun 2024 - Aug 2024

RAI Lab, KAIST

Research Intern · Prof. Jemin Hwangbo

Robust Recovery Controller for Quadruped Robot

Trained a recovery policy for the Raibo2 quadruped via deep RL in RaiSim. A 4-step reward curriculum addressed sparse rewards, while log-barrier rewards penalized violations of motor-aware hard constraints.

02Mar 2025 - May 2026

Rosota

Early Crew Member

RCM-Aware Imitation Learning for Laparoscopic Suturing

Developed an imitation learning pipeline for laparoscopic suturing using surgeon demonstrations, instrument sensing, digital twin feasibility checks, and trocar-adaptive diffusion policies.

03Jun 2025 - Oct 2025

Sequor Robotics

AI & Robotics Engineer Intern

Sim2Real Pipeline for Quadruped & Humanoid Robots

Built sim-to-real pipelines for deploying reinforcement learning policies trained in simulation on Unitree Go2 quadruped and G1 humanoid robots.

04Jul 2025 - Jul 2026

Robotics Lab, Seoul National University

Research Intern · Prof. Frank C. Park

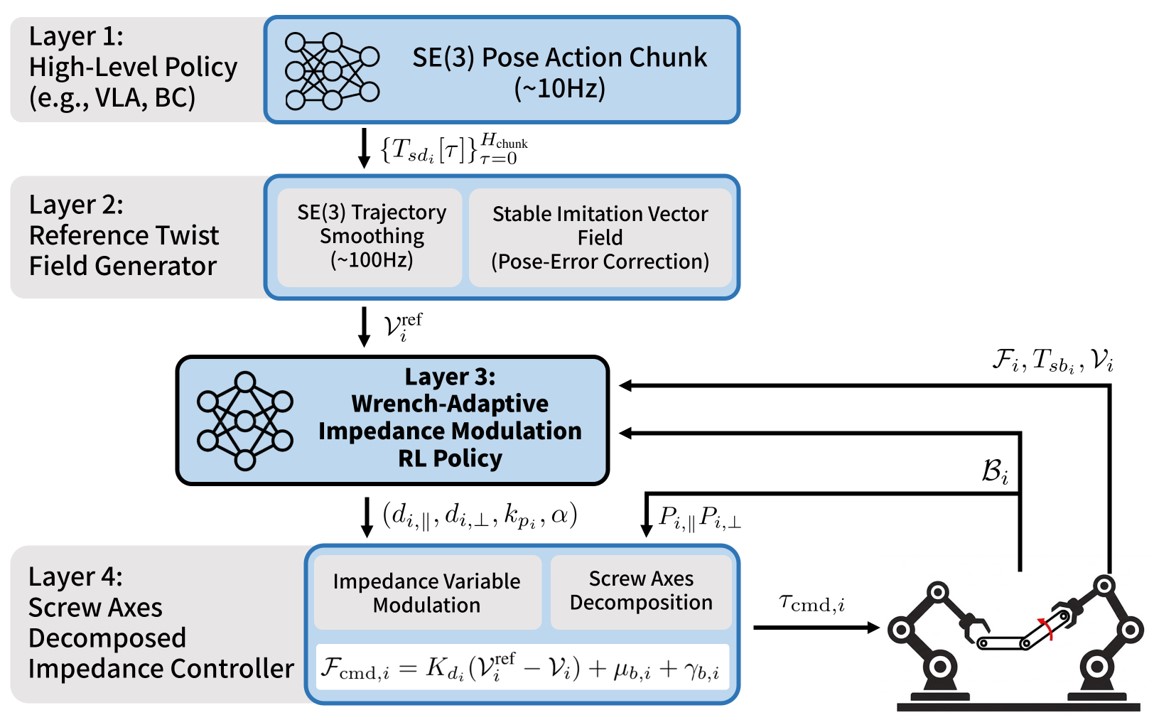
Impedance Control & Bimanual Manipulation

Conducted research on impedance control and bimanual manipulation, including a first-author CoRL 2026 paper.

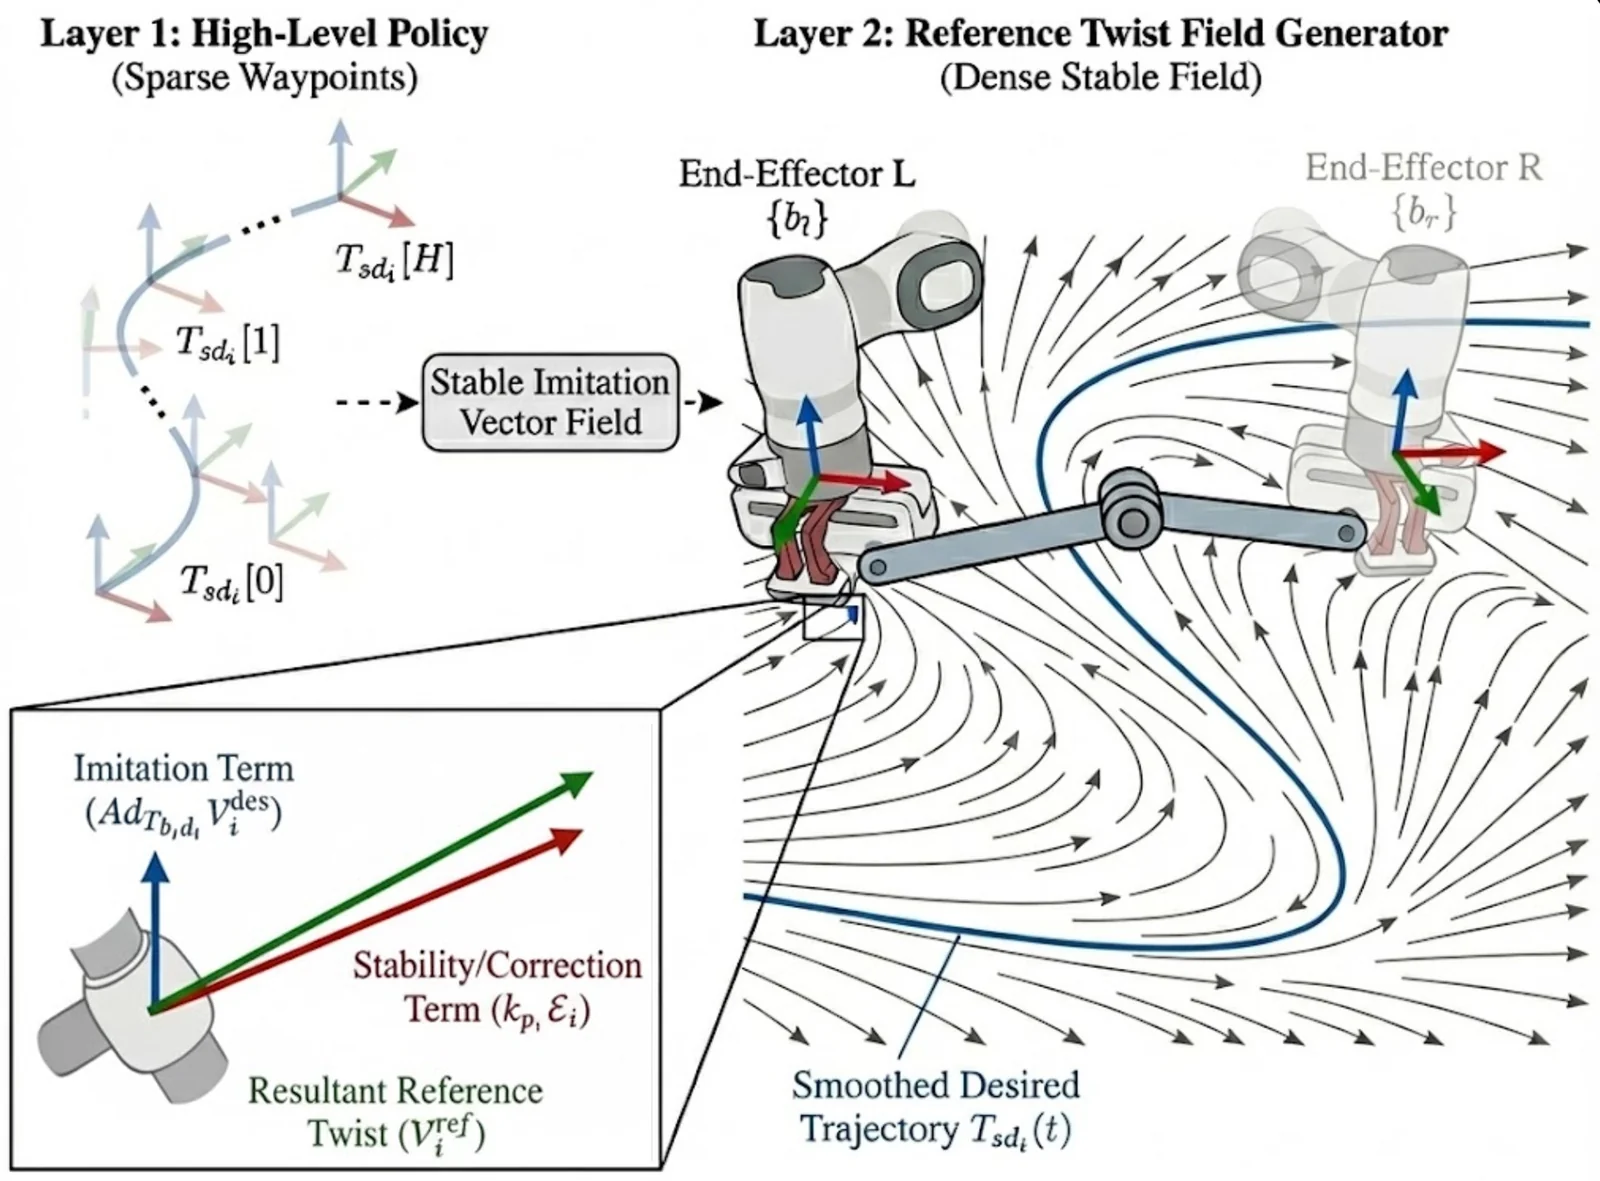
SWIVL reference twist field for bimanual manipulation
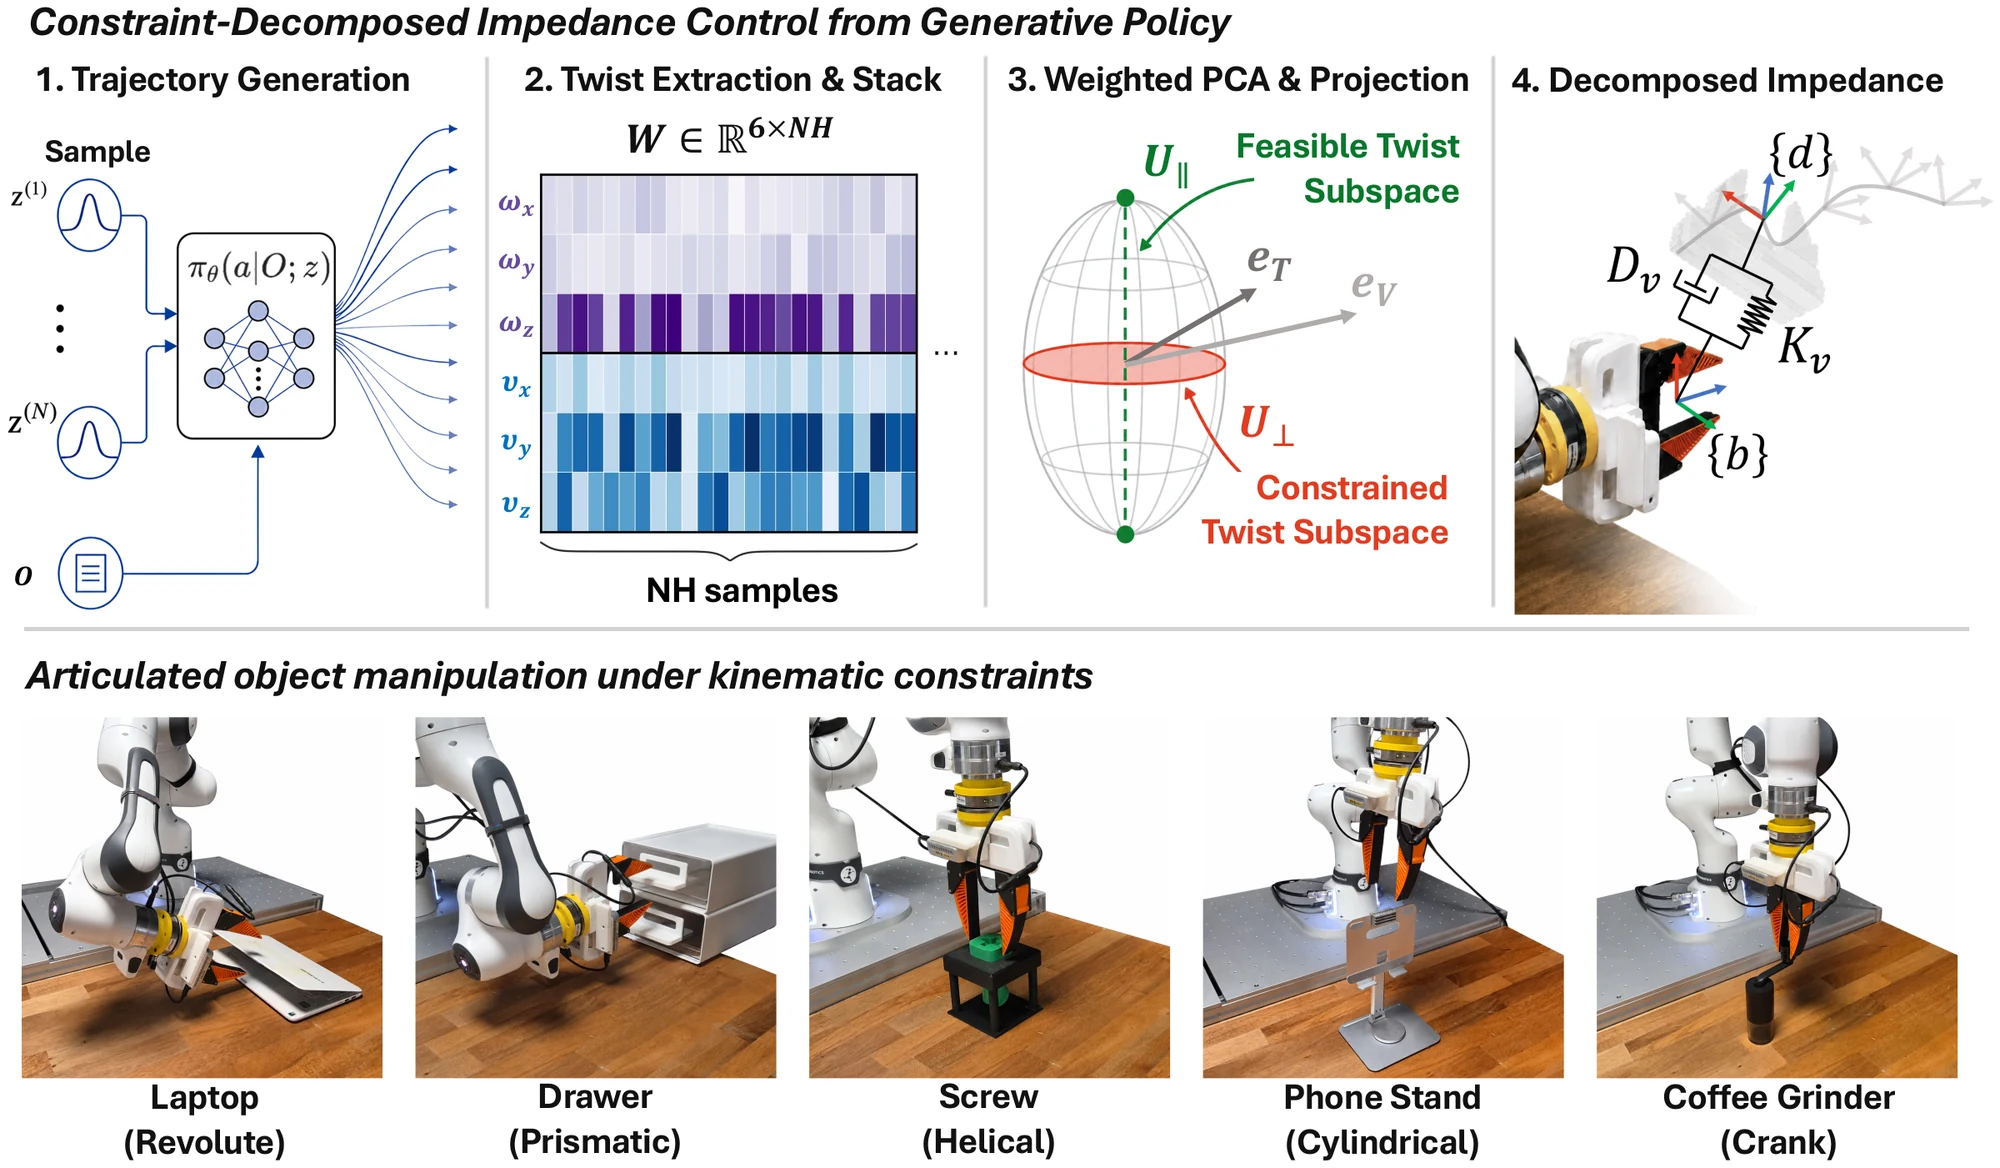
Constraint-Decomposed Impedance Control from Generative Policy method and real-world manipulation experiments

Featured Projects

All projects